Prof. Nikolaus Correll · University of Colorado Boulder
Introduction to Autonomous Robots
Manipulation from the CSCI 4302 labs: inverse kinematics, grasping, collision avoidance and bin picking with a robot arm.
5 lessons by Prof. Nikolaus Correll (University of Colorado Boulder), each with its theory and a Python controller you run on a Webots robot simulation in your browser, with nothing to install. Learn on your own, or assign the whole course to your class.
5 lessons
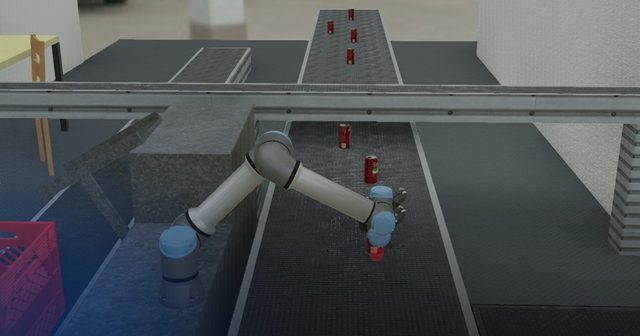
Inverse Kinematics
Move a UR5e arm with forward and inverse kinematics, joint and linear moves, and a safety plane.
Introduction to Autonomous Robots
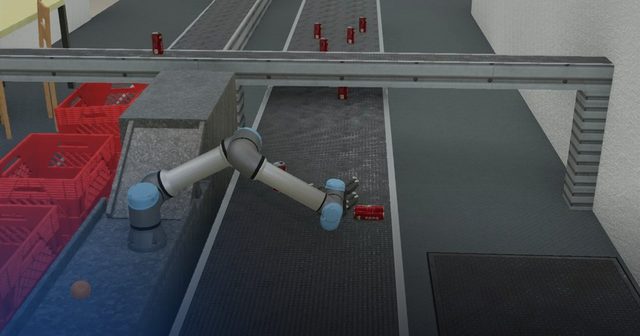
Simple Grasping
Find cans on a conveyor in a depth camera's point cloud and grasp one with a UR5e arm.
Introduction to Autonomous Robots
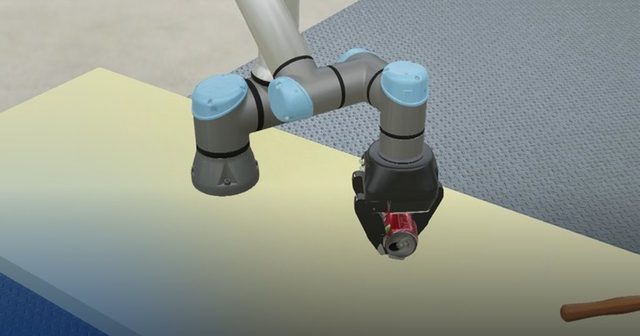
Oriented Grasping
Estimate a can's orientation from a point cloud and turn it into a top-down grasp for a UR5e.
Introduction to Autonomous Robots
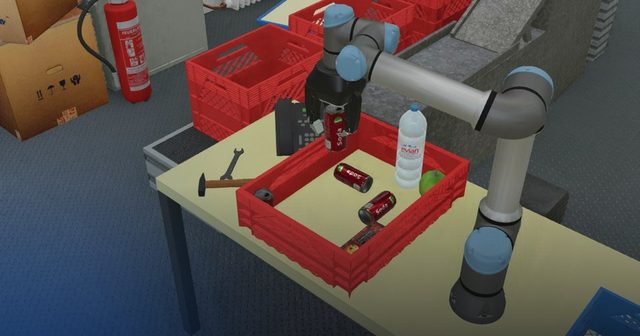
Collision Avoidance
Choose grasps that keep a UR5e's hand clear of a cluttered crate, checked in a collision world.
Introduction to Autonomous Robots
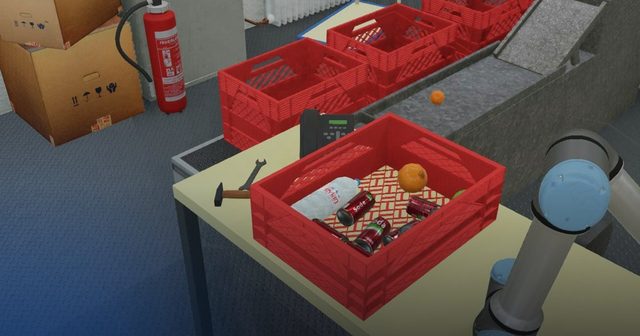
Bin Picking
Clear a cluttered bin with a UR5e arm, combining perception, grasping and a behavior tree.
Introduction to Autonomous Robots