Lesson catalog
Robotics lessons you can run in your browser.
Each lesson explains an algorithm and opens a ready-made Webots simulation: edit the controller, run it, watch the robot. Nothing to install.
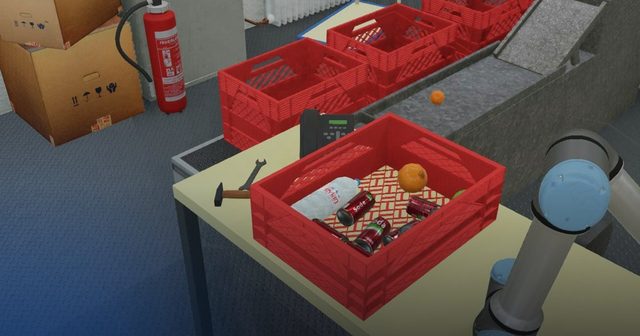
Bin Picking
Clear a cluttered bin with a UR5e arm, combining perception, grasping and a behavior tree.
Introduction to Autonomous Robots
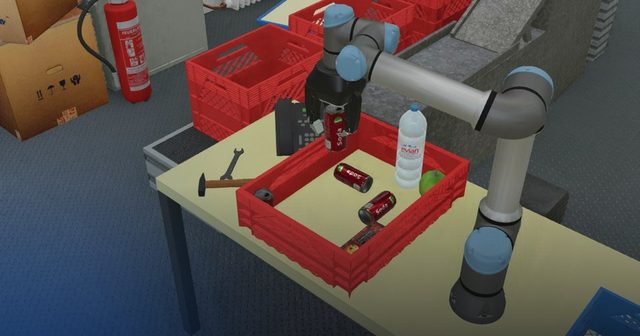
Collision Avoidance
Choose grasps that keep a UR5e's hand clear of a cluttered crate, checked in a collision world.
Introduction to Autonomous Robots
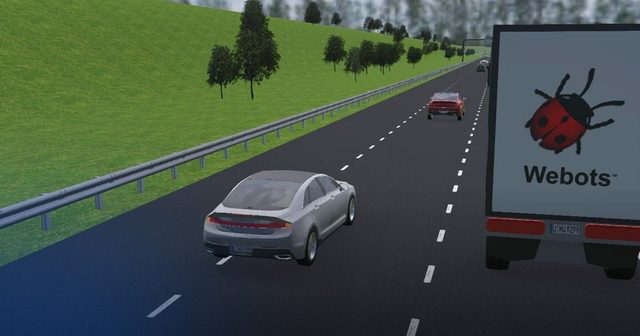
Highway Driving
Drive a car through highway traffic, keeping its lane and overtaking safely with Stanley steering.
Robot Programming Challenges
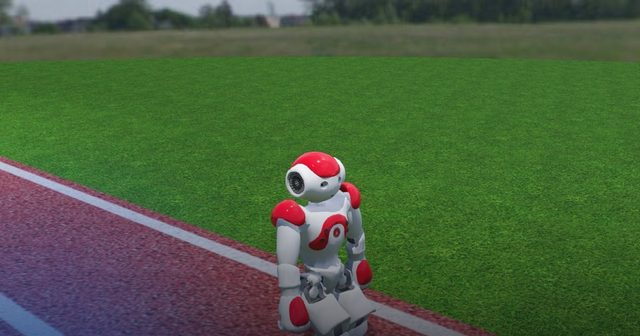
Humanoid Sprint
Make a NAO humanoid walk 10 meters as fast as it can without falling, with a gait you design.
Robot Programming Challenges
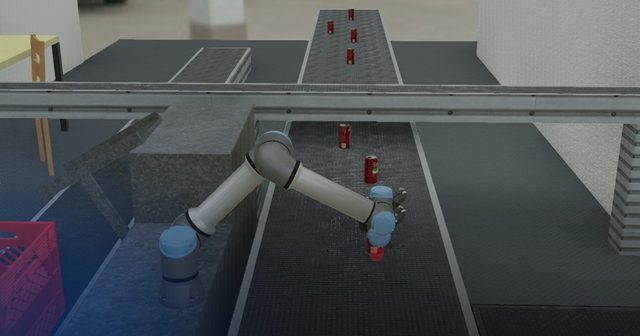
Inverse Kinematics
Move a UR5e arm with forward and inverse kinematics, joint and linear moves, and a safety plane.
Introduction to Autonomous Robots
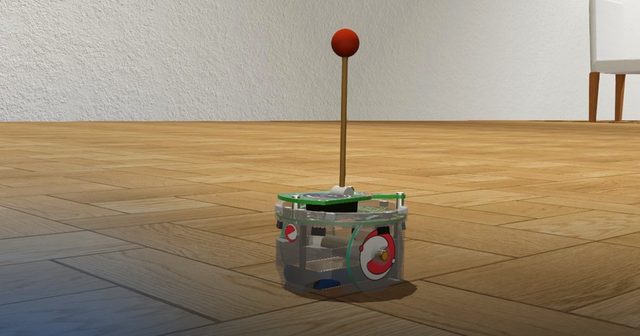
Inverted Pendulum Control
Keep a pole upright on a moving e-puck by tuning a PID controller on the pendulum's angle.
Robot Programming Challenges
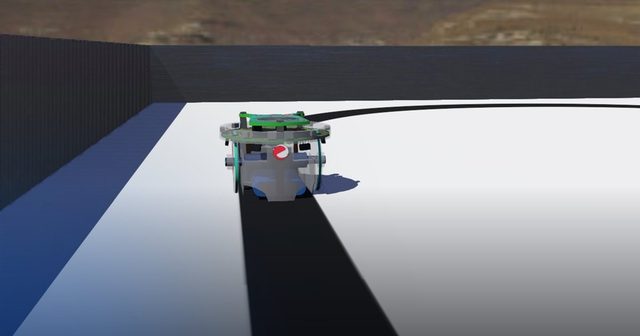
Line Following with Camera
Follow a dark line with an e-puck's camera by finding the line in each image.
Robotics Simulation Labs
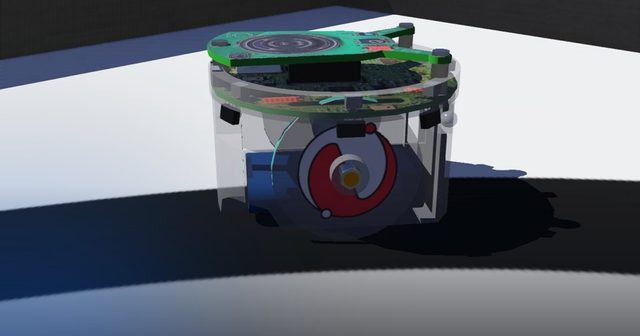
Line Following with Ground Sensors
Follow a dark line with an e-puck's ground sensors and a simple state machine.
Robotics Simulation Labs
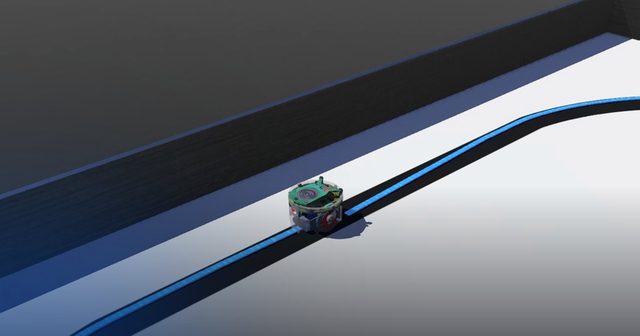
Line Following with Localization
Follow a line with an e-puck while estimating its pose from wheel odometry.
Robotics Simulation Labs
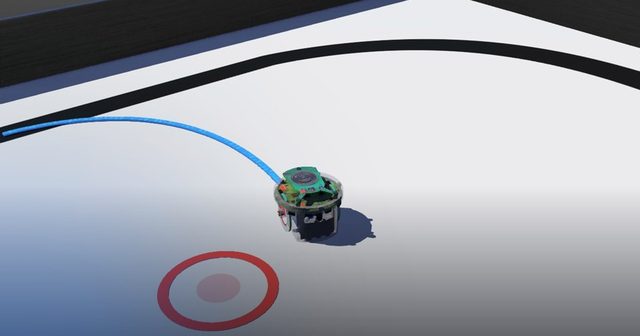
Navigation Controller (Odometry + PID)
Drive an e-puck to a goal position using wheel odometry and a PID controller.
Robotics Simulation Labs
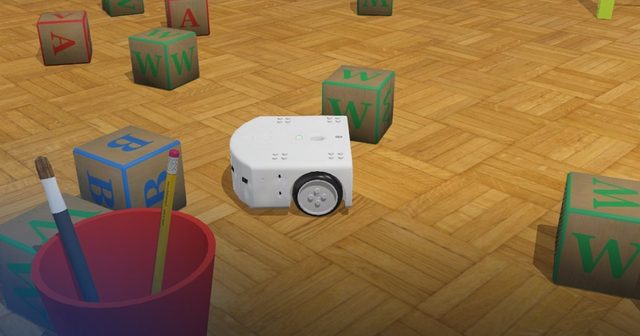
Obstacle Avoidance
Steer a Thymio through a cluttered classroom using its proximity sensors, without bumping into anything.
Robot Programming Challenges
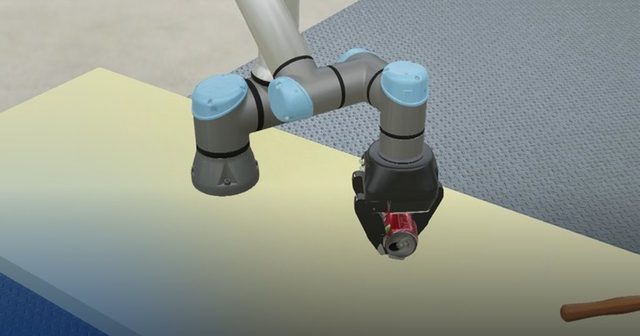
Oriented Grasping
Estimate a can's orientation from a point cloud and turn it into a top-down grasp for a UR5e.
Introduction to Autonomous Robots
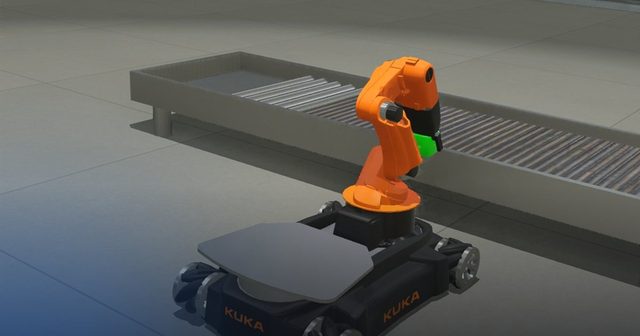
Pick & Place
Drive a KUKA youBot to grab a cube from a conveyor with its arm and place it in a cart's empty slot.
Robot Programming Challenges
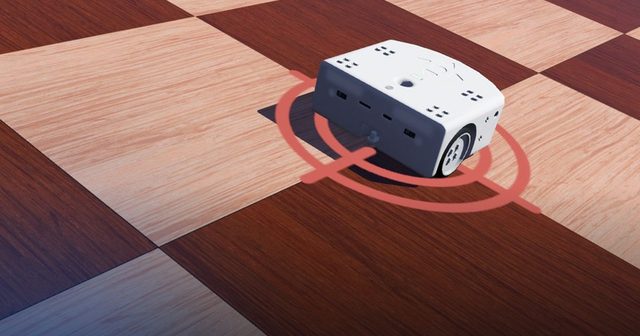
Robot Programming
Write your first controller: drive a Thymio exactly 25 cm forward and stop on the target.
Robot Programming Challenges
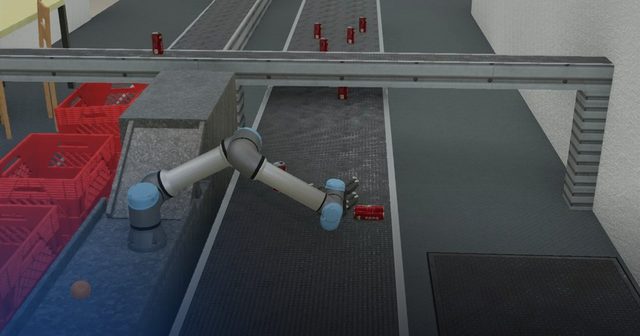
Simple Grasping
Find cans on a conveyor in a depth camera's point cloud and grasp one with a UR5e arm.
Introduction to Autonomous Robots
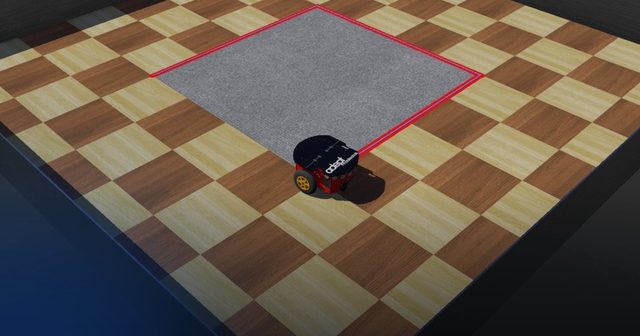
Square Path
Drive a Pioneer 3-DX around a 2-meter square using wheel odometry, returning to where it started.
Robot Programming Challenges
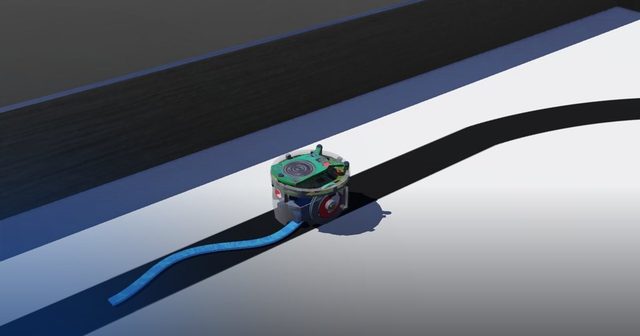
Trajectory Tracking Controller (Odometry + Kinematic Tracking)
Make an e-puck follow a planned trajectory using odometry and a kinematic tracking controller.
Robotics Simulation Labs
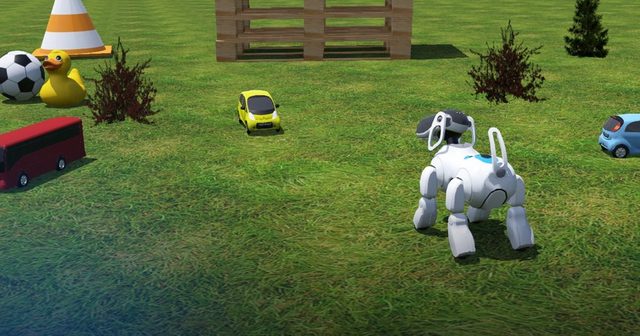
Visual Tracking
Make a robot dog track a moving rubber duck with its camera using color segmentation.
Robot Programming Challenges
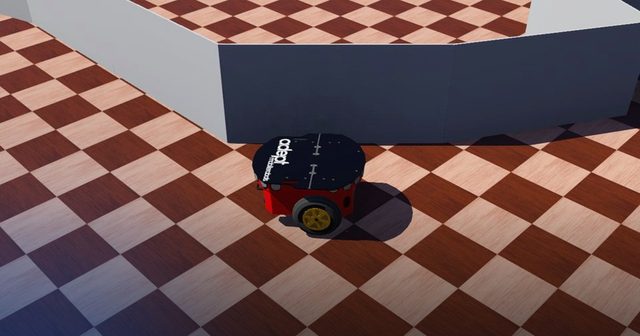
Wall Following
Keep a Pioneer 3-DX half a meter from the wall on its left using its sonar sensors.
Robot Programming Challenges
No lesson matches these filters.
Teaching robotics? Use these lessons as assignments.
Create a class, pick lessons, invite your students with a link, and see their submissions.