Prof. Felipe N. Martins · Hanze University of Applied Sciences
Robotics Simulation Labs
Mobile robot fundamentals in simulation: line following with ground sensors and cameras, odometry-based localization, PID navigation and trajectory tracking.
5 lessons by Prof. Felipe N. Martins (Hanze University of Applied Sciences), each with its theory and a Python controller you run on a Webots robot simulation in your browser, with nothing to install. Learn on your own, or assign the whole course to your class.
5 lessons
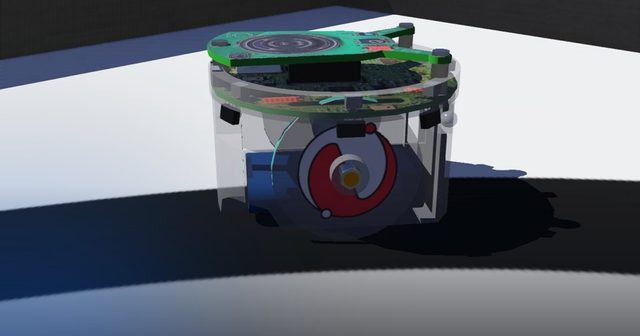
Line Following with Ground Sensors
Follow a dark line with an e-puck's ground sensors and a simple state machine.
Robotics Simulation Labs
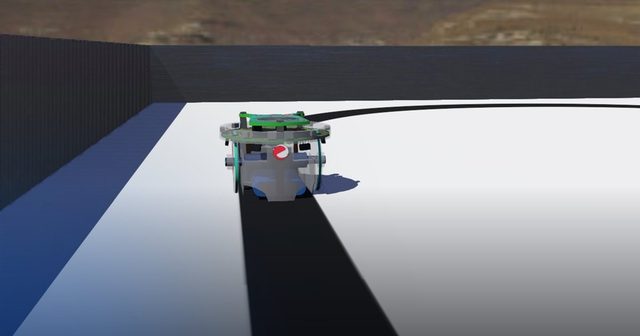
Line Following with Camera
Follow a dark line with an e-puck's camera by finding the line in each image.
Robotics Simulation Labs
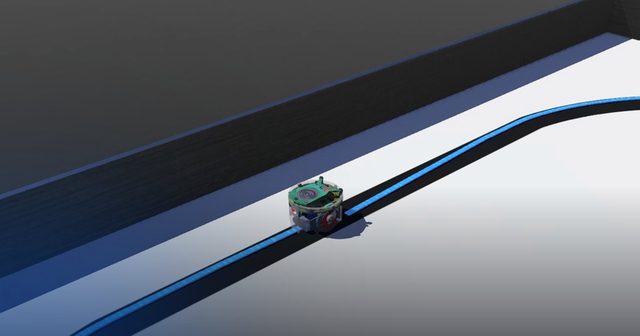
Line Following with Localization
Follow a line with an e-puck while estimating its pose from wheel odometry.
Robotics Simulation Labs
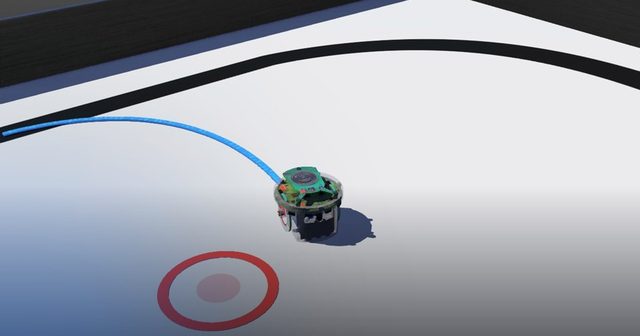
Navigation Controller (Odometry + PID)
Drive an e-puck to a goal position using wheel odometry and a PID controller.
Robotics Simulation Labs
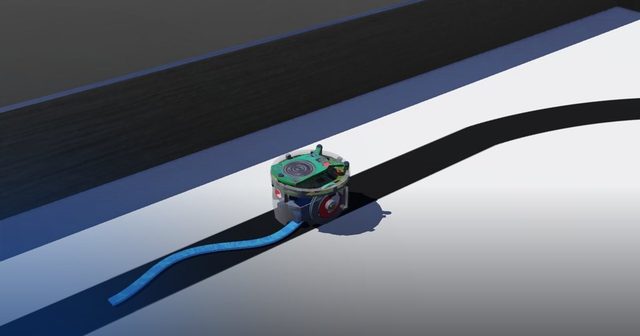
Trajectory Tracking Controller (Odometry + Kinematic Tracking)
Make an e-puck follow a planned trajectory using odometry and a kinematic tracking controller.
Robotics Simulation Labs