Cyberbotics & the Human Brain Project · robotbenchmark
Robot Programming Challenges
Classic robot programming challenges from robotbenchmark, from first steps to humanoid sprints: obstacle avoidance, wall following, highway driving, pick and place and more.
9 lessons by Cyberbotics & the Human Brain Project (robotbenchmark), each with its theory and a Python controller you run on a Webots robot simulation in your browser, with nothing to install. Learn on your own, or assign the whole course to your class.
9 lessons
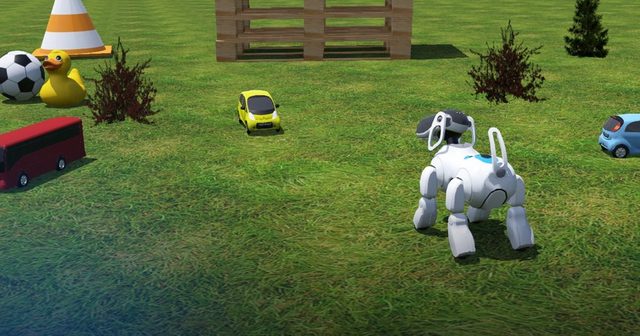
Visual Tracking
Make a robot dog track a moving rubber duck with its camera using color segmentation.
Robot Programming Challenges
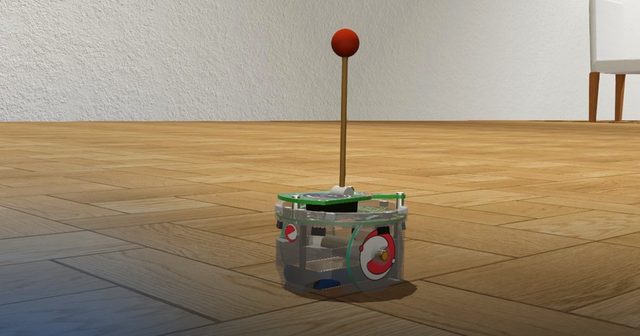
Inverted Pendulum Control
Keep a pole upright on a moving e-puck by tuning a PID controller on the pendulum's angle.
Robot Programming Challenges
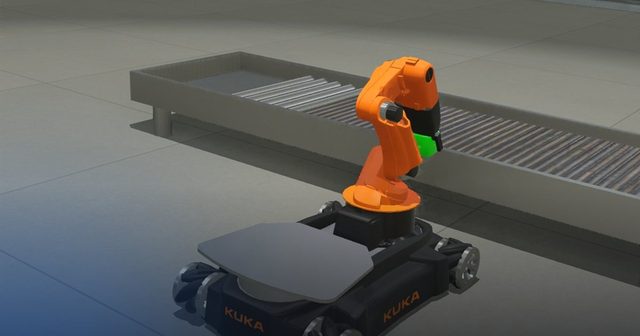
Pick & Place
Drive a KUKA youBot to grab a cube from a conveyor with its arm and place it in a cart's empty slot.
Robot Programming Challenges
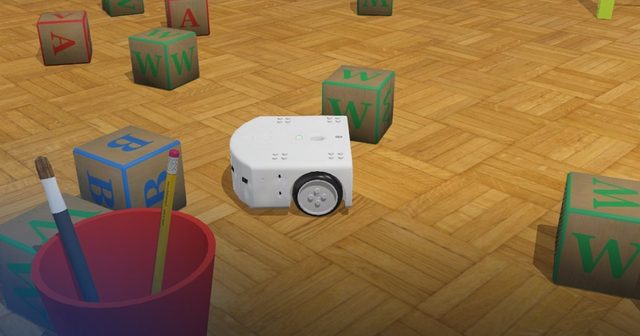
Obstacle Avoidance
Steer a Thymio through a cluttered classroom using its proximity sensors, without bumping into anything.
Robot Programming Challenges
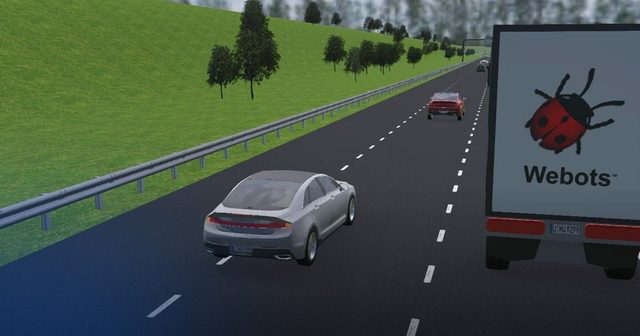
Highway Driving
Drive a car through highway traffic, keeping its lane and overtaking safely with Stanley steering.
Robot Programming Challenges
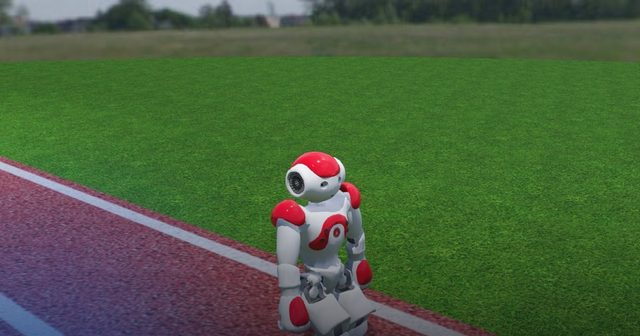
Humanoid Sprint
Make a NAO humanoid walk 10 meters as fast as it can without falling, with a gait you design.
Robot Programming Challenges
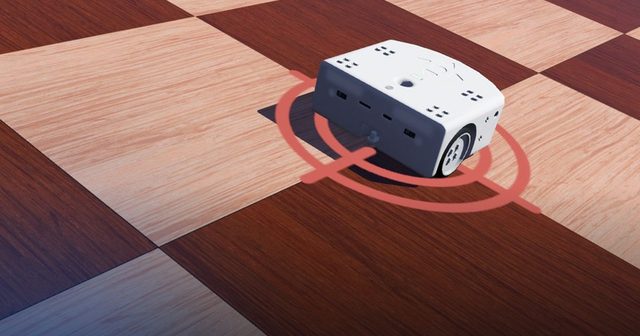
Robot Programming
Write your first controller: drive a Thymio exactly 25 cm forward and stop on the target.
Robot Programming Challenges
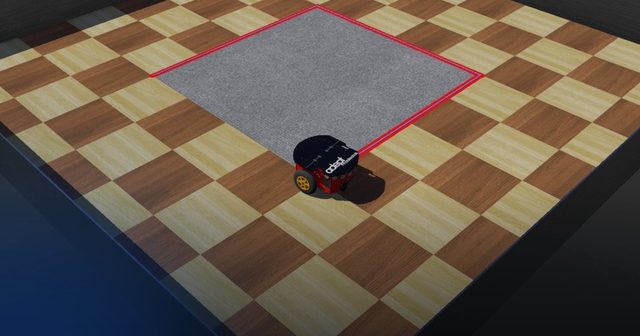
Square Path
Drive a Pioneer 3-DX around a 2-meter square using wheel odometry, returning to where it started.
Robot Programming Challenges
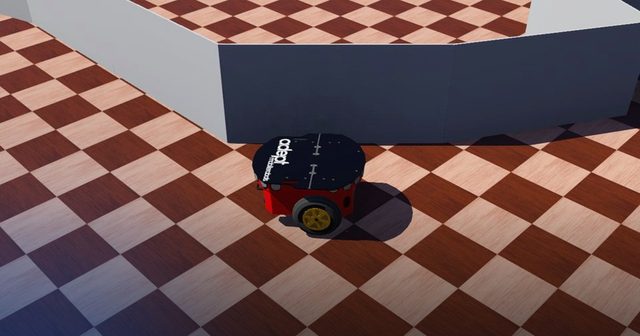
Wall Following
Keep a Pioneer 3-DX half a meter from the wall on its left using its sonar sensors.
Robot Programming Challenges